
Self-balancing Robot
Project overview
The Self-balancing Robot is an innovative solution in the field of personal robotics, combining advanced programming technologies with practical user application. The creation of a self-balancing robot allows for the exploration of modern control algorithms such as PID algorithms. The robot maintains balance thanks to precise sensor data readings, enabling smooth movement and stabilization in various conditions.
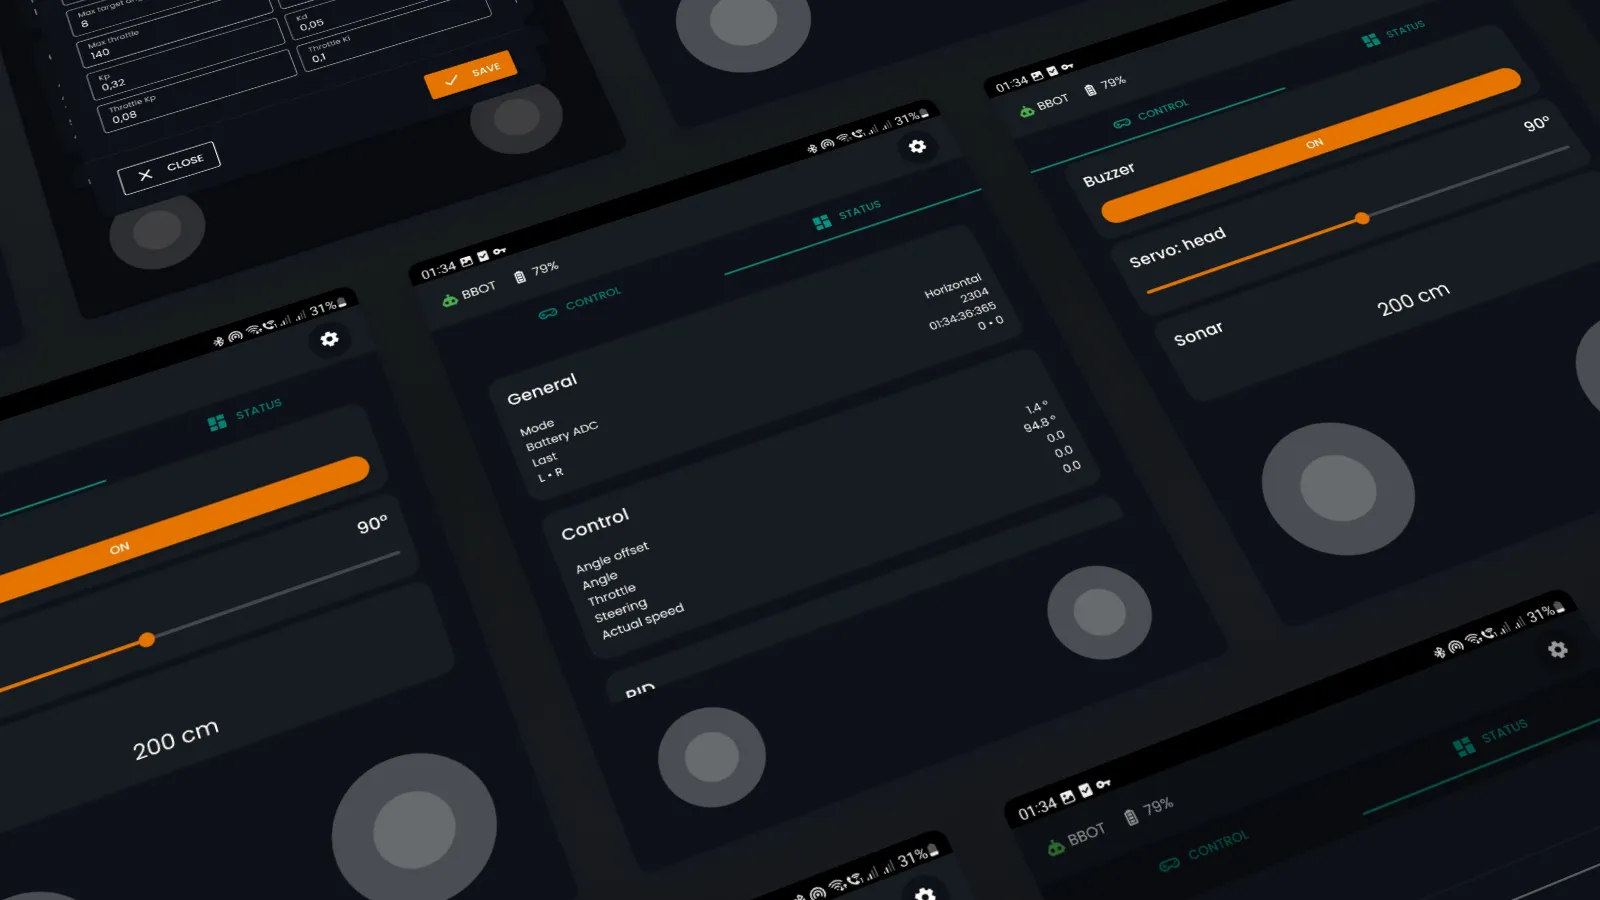
The mobile application, developed using the latest web and mobile technologies like Vue and TypeScript, allows remote control of the robot and complete monitoring of its status. The user interface is intuitive and provides the capability to adjust balance parameters, allowing users to optimize the robot’s capabilities. Communication between the application and the robot is accomplished via WiFi, ensuring fast and reliable data transmission.
The microcontroller part is programmed in C++, ensuring high performance and reliability of the device operation. The entire system integrates into a cohesive management unit, enabling not only remote control but also the handling of additional features such as auto drive or position control. These options enhance the robot’s functionality and versatility in educational and experimental applications.
Technologies


